Oct 20, 2026
single-axis-PID
I changed my mind - of course I'm broke :)
Action plan to finally complete this PID project using the IMU sensor. THe flight controller project seemed to be expensive, and hence this is an alternative project with the same concepts.
Field note
The Problem
I tried to compile the list of items to order for the flight controller and realised it was actually crossing 100 EUR, which honestly is out of my budget. The major contributors were definitely the brushless motors, battery and the battery charger. The ESC was still understandable, but buying 1 LiPo battery and then keeping the battery charger for just one of it just seems very stupid.
And hence, I thought - well there might be something else I can do instead? What about balancing an inverted pendulum. Well not exactly a pendulum, but let's say a self-balancing robot.
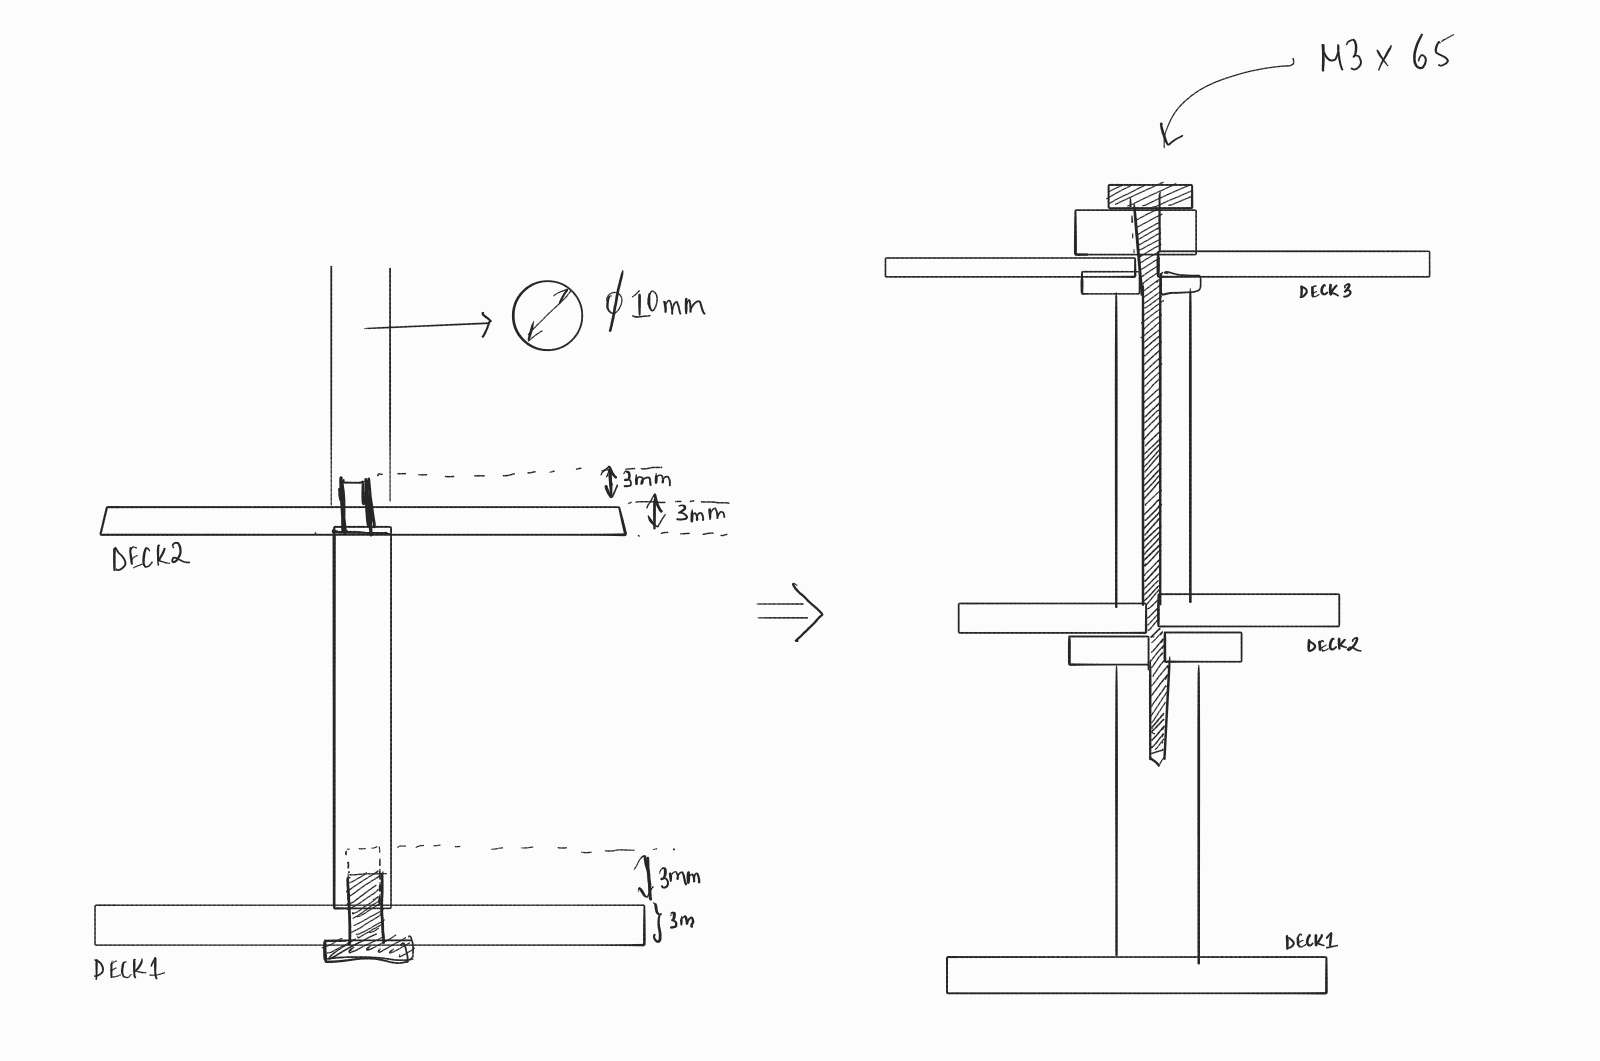
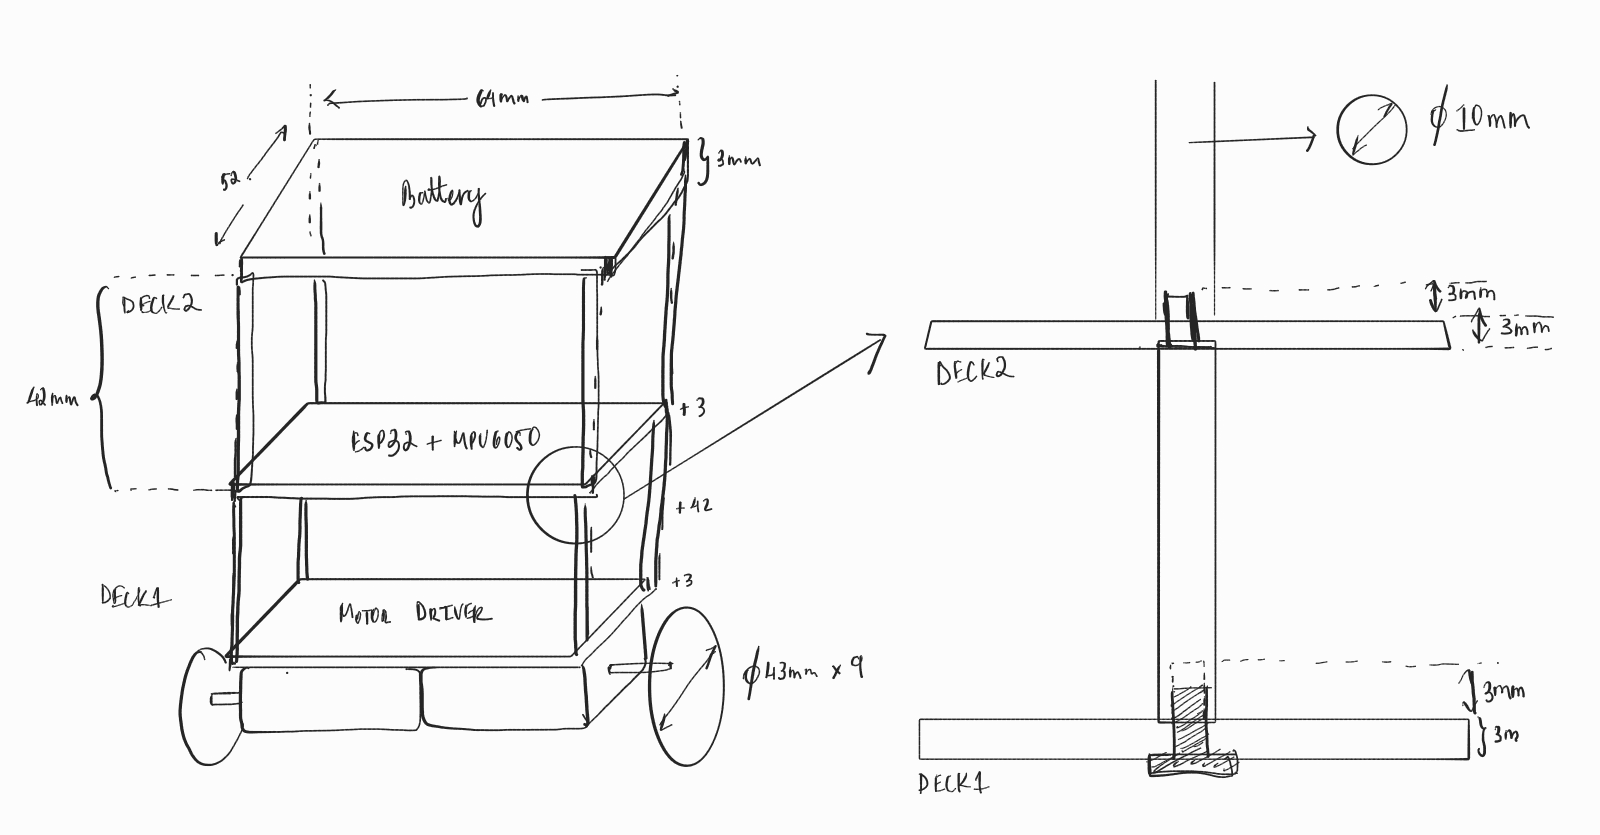 Now, I had to make myself teach CAD design in one day, but thanks to AI, yeah its pretty easy to learn any software now. My first version of the design ought to use multiple screws to hold the pillar to the decks, but then again I think I was being a miser, I re-designed it such that it now uses M3 x 65 x 4 screw heads, going all throught he pillars from deck 3 to deck 1.
 I would also add some fillets on the base of the standoffs/pillars for stability and so that it doesn't break easily if the structure falls.
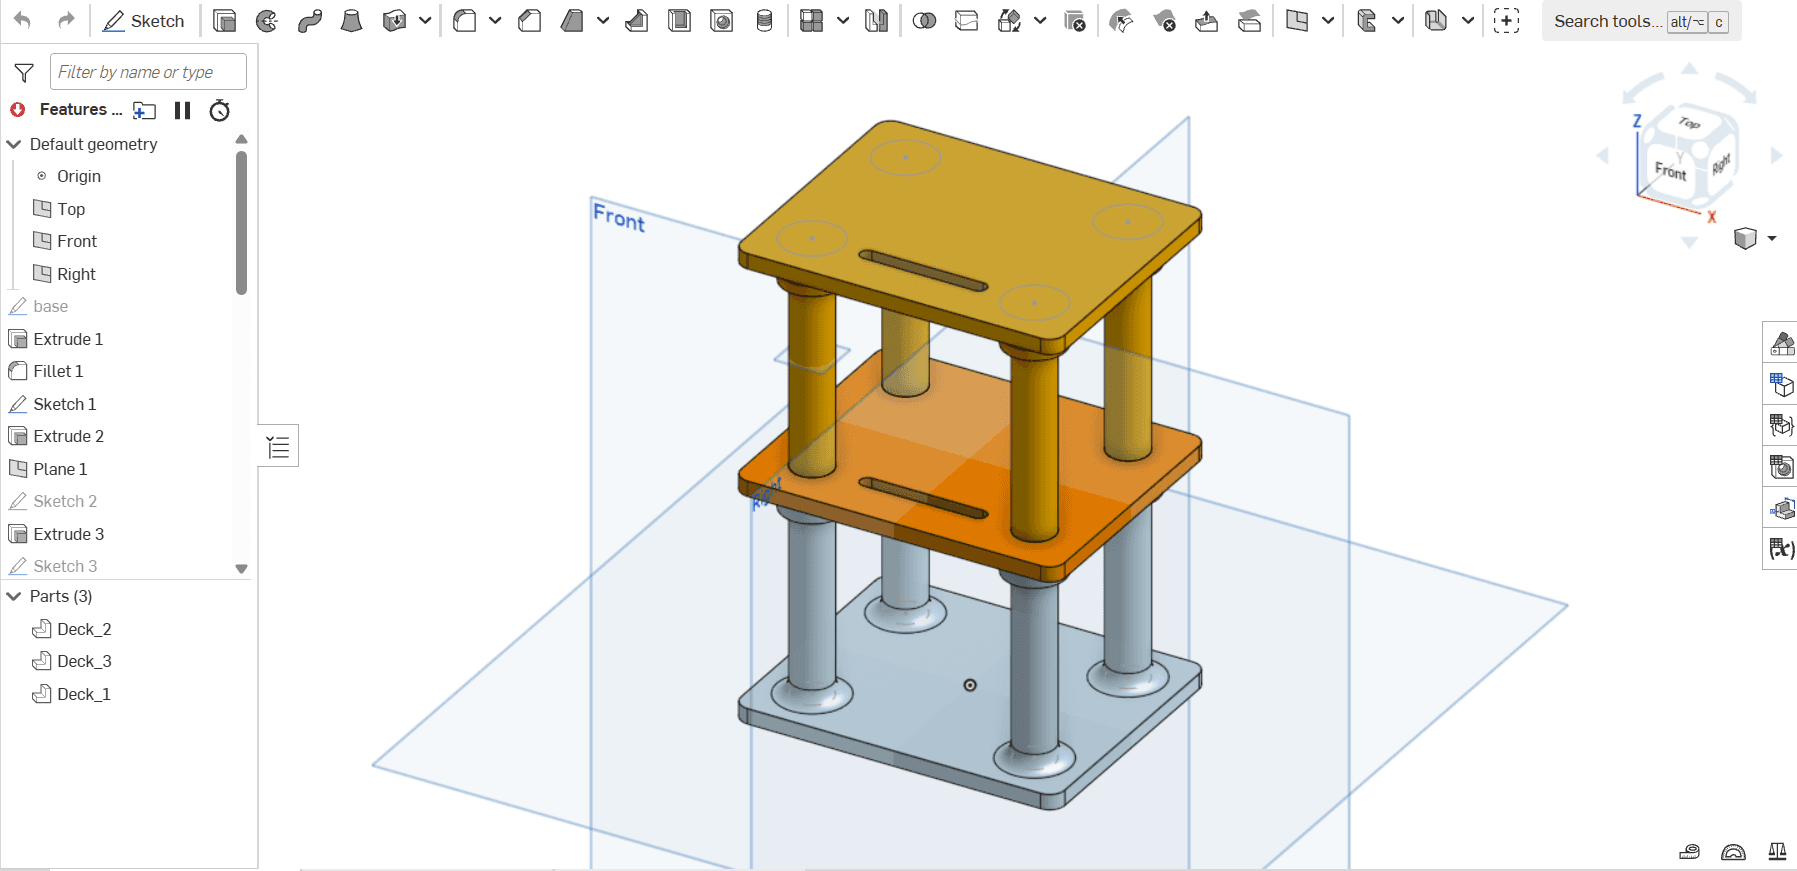 I haven't added any holes for mounting the electronics components, which I think is definitely a dumb idea, yea I'll add them after this. The next part is implementing the inner loop and testing the software part using serial telemetry.